Arduino C++ Embedded Systems Robotics IR Sensors
Line-Following Autonomous Robot
Freshman Engineering Project
Role: Student Engineer Date: Freshman Year
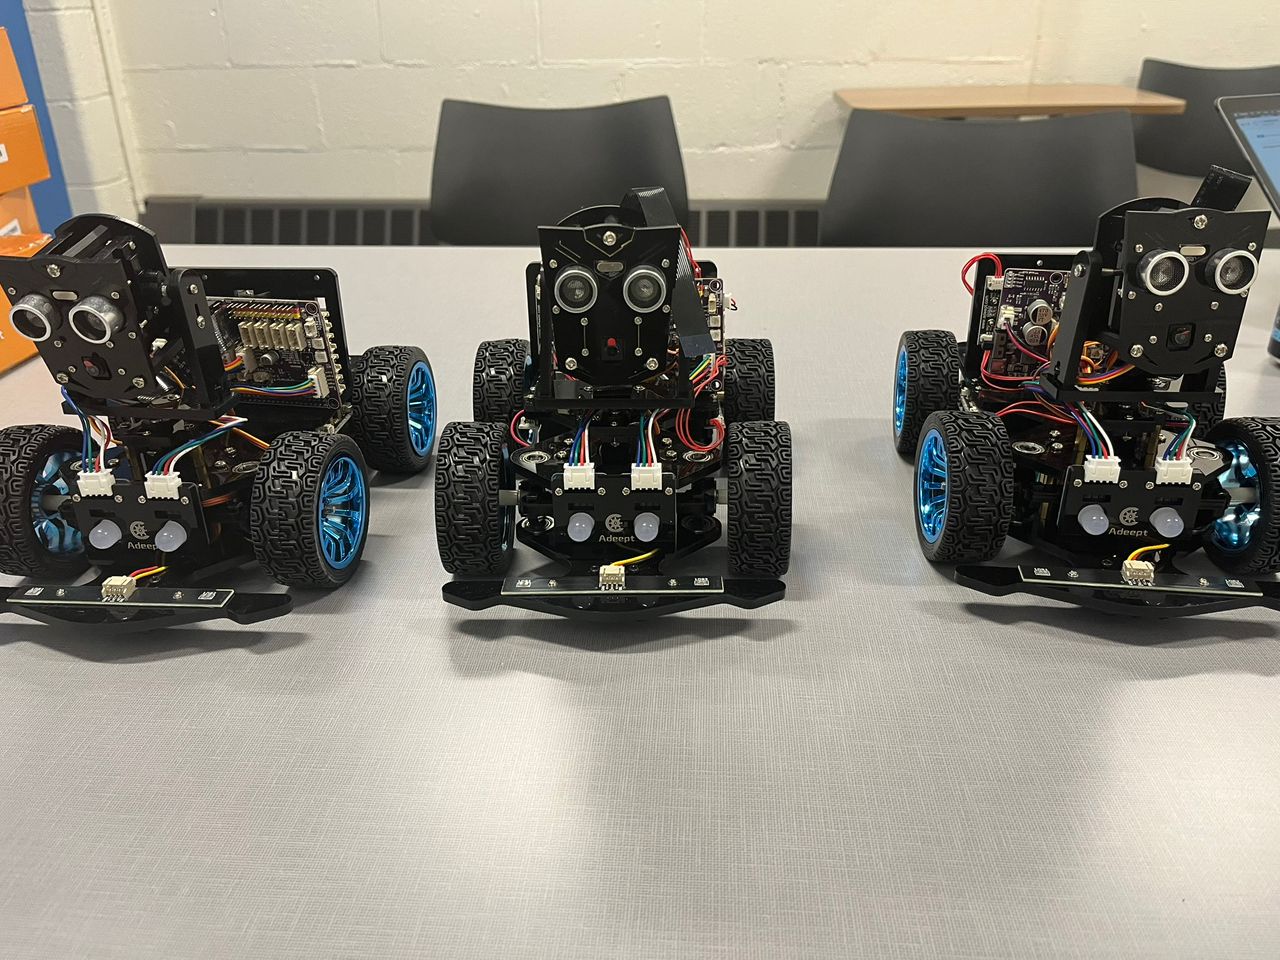
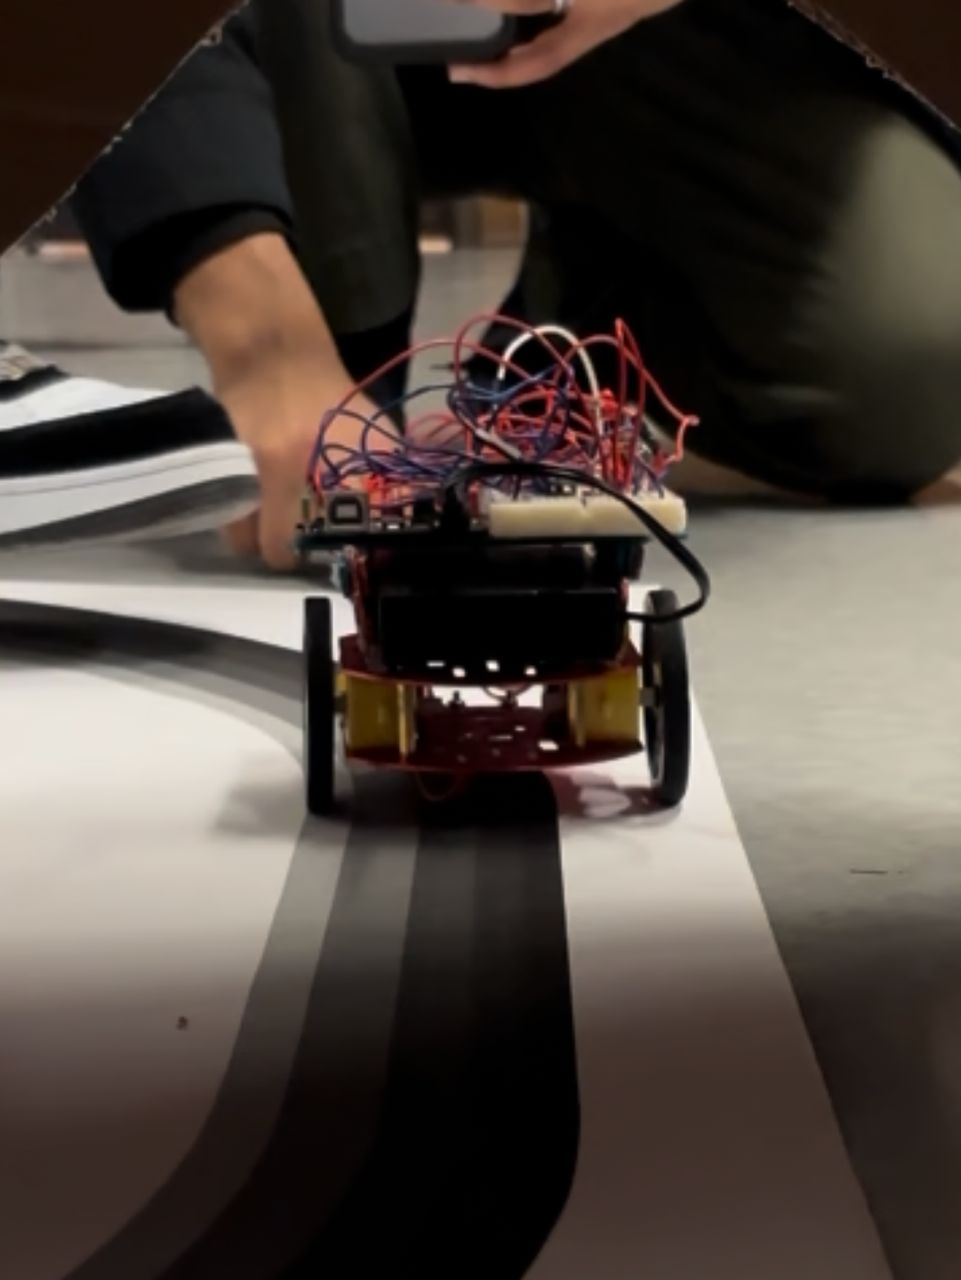
Fully functional line-following robot using Arduino and infrared sensors with real-time motor control.
Result
Successfully achieved stable line tracking with consistent motor response and minimal deviation from path. This wasn't just about coding — I had to troubleshoot wiring issues, motor inconsistencies, and sensor misreadings before getting smooth motion.
View Project →